poisson_source — source recovery for the Poisson equation (elliptic PDE)¶
| At a glance | |
|---|---|
| Problem | The source of the Poisson equation from sparse, boundary or full observations of the potential |
| Unknown | source f ≥ 0 (softplus head), 64² |
| Physics | −κΔu = f with Dirichlet boundaries, solved exactly by a spectral (DST) solver — a hard constraint, never a residual |
| Measurement | potential u on a random 10 % of the pixels (default), a boundary strip or everywhere; data by finite differences on a 2× grid in float64 |
| Difficulty classes | blobs, points, smooth |
| Baselines | grid, deep_decoder |
| Metrics | PSNR · MSE · relative error |
| Run | nefi run poisson_source --smoke · full: nefi run configs/poisson_source_full.yaml |
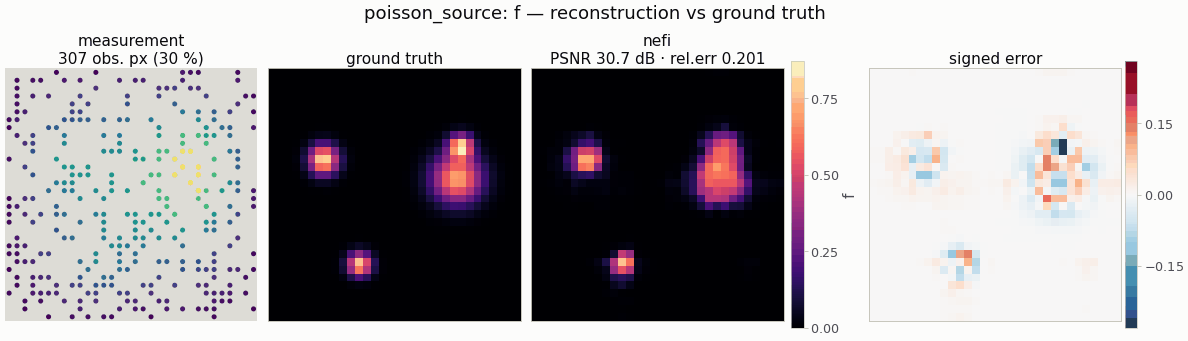
Gallery run (smoke preset: 32², 30 % of the potential observed; 600 steps, 0.6 s on a CPU): PSNR 30.7 dB, all three sources found.
Recover a non-negative source f on the unit square from noisy observations of the potential u
observed on a sparse random subset of pixels (obs_fraction, default 10 %), on a boundary strip
(boundary_width cells) or everywhere. The PDE is a hard constraint: the unknown is f and u
is always the exact discrete solution (NeFTY §4.2 design principle), never a soft residual.
from nefi.instances.poisson_source import PoissonSource
inst = PoissonSource(n=64, scene="points", obs_mode="boundary")
out = inst.run(seed=0)
out.metrics                   # {"psnr", "mse", "relative_error"}
nefi run poisson_source --smoke, nefi run configs/poisson_source_full.yaml.
Example: python examples/poisson_source.py [--set obs_mode=boundary --set scene=smooth].
Differentiable spectral solver (nefi.instances.poisson_source.operator)¶
On the cell-centered grid x_i = (i + ½) h with Dirichlet conditions on the cell faces, the
Laplacian's eigenfunctions sin(mπx/L) sampled at the cell centers form the DST-II basis, so
dst2/idst2 (and the node-centered dst1/idst1) are implemented with real FFTs of odd
extensions (torch.fft.rfft/irfft; no scipy in the differentiable path, device-agnostic,
batched, any axis; they match scipy.fft.dst(type=2|1) / 2 to 1e-15). PoissonOperator returns the
full u grid, is linear (homogeneity = 1), works in 1-3 D and caches eigenvalues per
resolution; laplacian(u) applies the inverse map. spectrum="fd" uses the eigenvalues
(4/h²) sin²(mπh/2L) of the 5-point Laplacian with antisymmetric ghost cells and therefore
reproduces the finite-difference solution exactly.
Observations, masks and coarse stages¶
The operator predicts u everywhere; the Measurement.mask selects the observed pixels, so the
data term is a masked mean (unobserved pixels carry data = 0 and are ignored). Coarse curriculum
stages use masked_downsample (installed as InverseProblem.downsample_obs): the coarse datum is
the mean of the observed fine pixels in a cell and the coarse mask is the observed fraction
(a weight), instead of thresholding an area-averaged binary mask — which would discard most cells
of a 10 % random mask.
Data generation (inverse-crime guard) and scenes¶
PoissonDataGenerator solves the PDE with an independent discretization: a sparse 5-point
finite-difference system on a 2× finer grid in float64 (fd_poisson_solve, scipy SuperLU), area-
averages u to the native grid, draws the mask with the scene's numpy generator and adds relative
Gaussian noise (fidelity_tag = "poisson-fd-2x-float64"; the inversion operator is tagged
"poisson-dst-continuous-1x"). Scenes (SourceScenes, cell-averaged, maximum ≈ 1, interior
[0.2, 0.8]²): blobs (2-4 compact Gaussians), points (3-6 near-point sources of width
point_cells native cells), smooth (broad overlapping blobs).
Prior, objective and curriculum¶
Neural field with a Softplus (non-negative) or Identity head; data = masked
relative MSE (‖pred − obs‖² / ‖obs‖² over observed pixels — scale-free, because u is
orders of magnitude smaller than f; data_loss="mse" for the plain masked MSE), l1 and
isotropic tv on f. Source recovery is the most ill-conditioned of the three imaging instances
((−Δ)⁻¹ damps frequency k by 1/k²), so first-order methods converge slowly: the default
curriculum is 1000 + 2000 steps (with full, low-noise data 450 steps give PSNR 23.3 dB / relative
error 0.47, 2000 steps 32.0 dB / 0.17 at 32²).
Configuration (PoissonSourceConfig)¶
| field | default | meaning |
|---|---|---|
n, extent, conductivity |
64, 1.0, 1.0 | grid, side length, κ |
spectrum |
continuous |
eigenvalues of the inversion solver: continuous | fd |
scene, point_cells |
blobs, 0.8 |
blobs | points | smooth; point-source width |
obs_mode, obs_fraction, boundary_width |
random, 0.1, 3 |
random | boundary | full |
noise_std |
0.01 | relative to max |u| |
supersample |
2 | FD data-generation grid factor |
head, init_value |
softplus, 0.05 |
softplus | identity |
data_loss |
relative_mse |
relative_mse | mse |
l1, tv, tv_eps |
1e-3, 1e-4, 1e-3 | regularizers |
hidden, depth, skip_at, n_octaves, activation |
128, 4, 2, 6, tanh | neural field |
steps, lr, lr_decay, anneal_fraction |
(1000, 2000), 1e-2, 0.5, 1.0 | curriculum |
grid_lr |
5e-2 | grid baseline |
dd_lr, dd_width, dd_stages |
5e-3, 64, 5 | Deep Decoder baseline |
Configs: configs/poisson_source_smoke.yaml (32², 30 % random observations, 200 + 400 steps,
~1-2 s CPU; also the gallery preset), configs/poisson_source_full.yaml (64², 10 %, 2000 + 4000
steps).
The smoke preset changes the prior, not only the size: a ReLU field (activation: relu)
with a faster annealing ramp (anneal_fraction: 0.5) and a stronger TV (tv: 5e-4). With the
full config's tanh field and anneal_fraction = 1 the compact blobs only become representable at
the very end of each stage and the weakest one is never found in a few hundred steps — the
optimizer, not the objective, is the bottleneck (the free TV grid with the identical objective
recovers it). Over seeds 0-3 the smoke preset gives 30.7 / 29.0 / 28.4 / 28.2 dB (relative error
0.20-0.28) with every blob recovered.
Baselines (PoissonSource.baselines())¶
grid (free source pixels, same objective) and deep_decoder; any other kind via
nefi.baselines.baseline_problem (all keep the mask-aware downsample_obs).
Validation¶
tests/test_poisson_source.py (≈ 12 s). Measured values:
| check | result |
|---|---|
DST-I / DST-II vs scipy.fft.dst / 2, round trips, any axis |
≤ 1e-12 |
analytic eigenfunction f = 2π² sin(πx) sin(πy) → u = sin(πx) sin(πy) (n = 32/64/128) |
relative error 3.8e-16 / 2.6e-16 / 2.5e-16 (also for extent 2, κ = 0.5) |
spectrum="fd" vs scipy sparse 5-point FD |
1.4e-14 relative |
| continuous spectrum vs FD, n = 16 / 32 / 64 | 1.3e-2 / 3.5e-3 / 8.8e-4 (second order) |
torch.autograd.gradcheck through the solver |
passes |
| masked MSE: values at unobserved pixels (data or prediction) | no effect on the loss |
Inversion (seed 0, blobs, 1 % noise; baselines at the same step budget):
| setting | neural field | grid | Deep Decoder |
|---|---|---|---|
| 32², 10 % observed, tanh, 450 steps | 22.23 dB / rel. err 0.531 (3.9 s) — 2 of 3 blobs | 23.27 / 0.471 (1.3 s) | 21.63 / 0.569 |
| 32², smoke (30 % observed, ReLU, 600 steps) | 30.65 / 0.201 (≈ 1 s) — all 3 blobs | 27.96 / 0.274 | 25.01 / 0.385 |
| 64², 1000 + 2000 steps (10 %) | 27.57 / 0.315 (185 s*) | 29.96 / 0.239 (20 s*) | 32.08 / 0.187 (233 s*) |
(* wall-clock on a CPU, indicative only.) Source recovery through the smoothing
(−Δ)⁻¹ rewards strongly smoothing parameterizations: at the full config the Deep Decoder's
global low-pass G_θ fits the compact blobs best and the TV grid beats the tanh neural field;
with no explicit prior the grid is still regularized by early stopping (docs/baselines.md). The
smoke preset's ReLU field with a short annealing ramp reverses the ranking at 32². Single seed
per row — use nefi bench for CIs and the points / boundary regimes.
Notes and limitations¶
- Homogeneous Dirichlet conditions on a rectangle only (the DST diagonalizes exactly that); other
boundary conditions need DCT variants or an iterative solver (
nefi/operators/pde). - Constant conductivity; a spatially varying
κ(x)turns this into the Darcy/EIT-type coefficient problem. - With boundary-strip observations the problem is severely ill-posed (only the far field of the sources is seen); expect depth/size ambiguity rather than sharp recovery.